I am currently a Machine Learning Engineer at Waymo, where I work on world models for autonomous driving.
Before that, I was at Zoox working on the autonomous vehicle's collision avoidance system.
I previously completed my Ph.D. in Robotics with the DECAR
Group at McGill university, under the supervision of James Forbes and David Saussié.
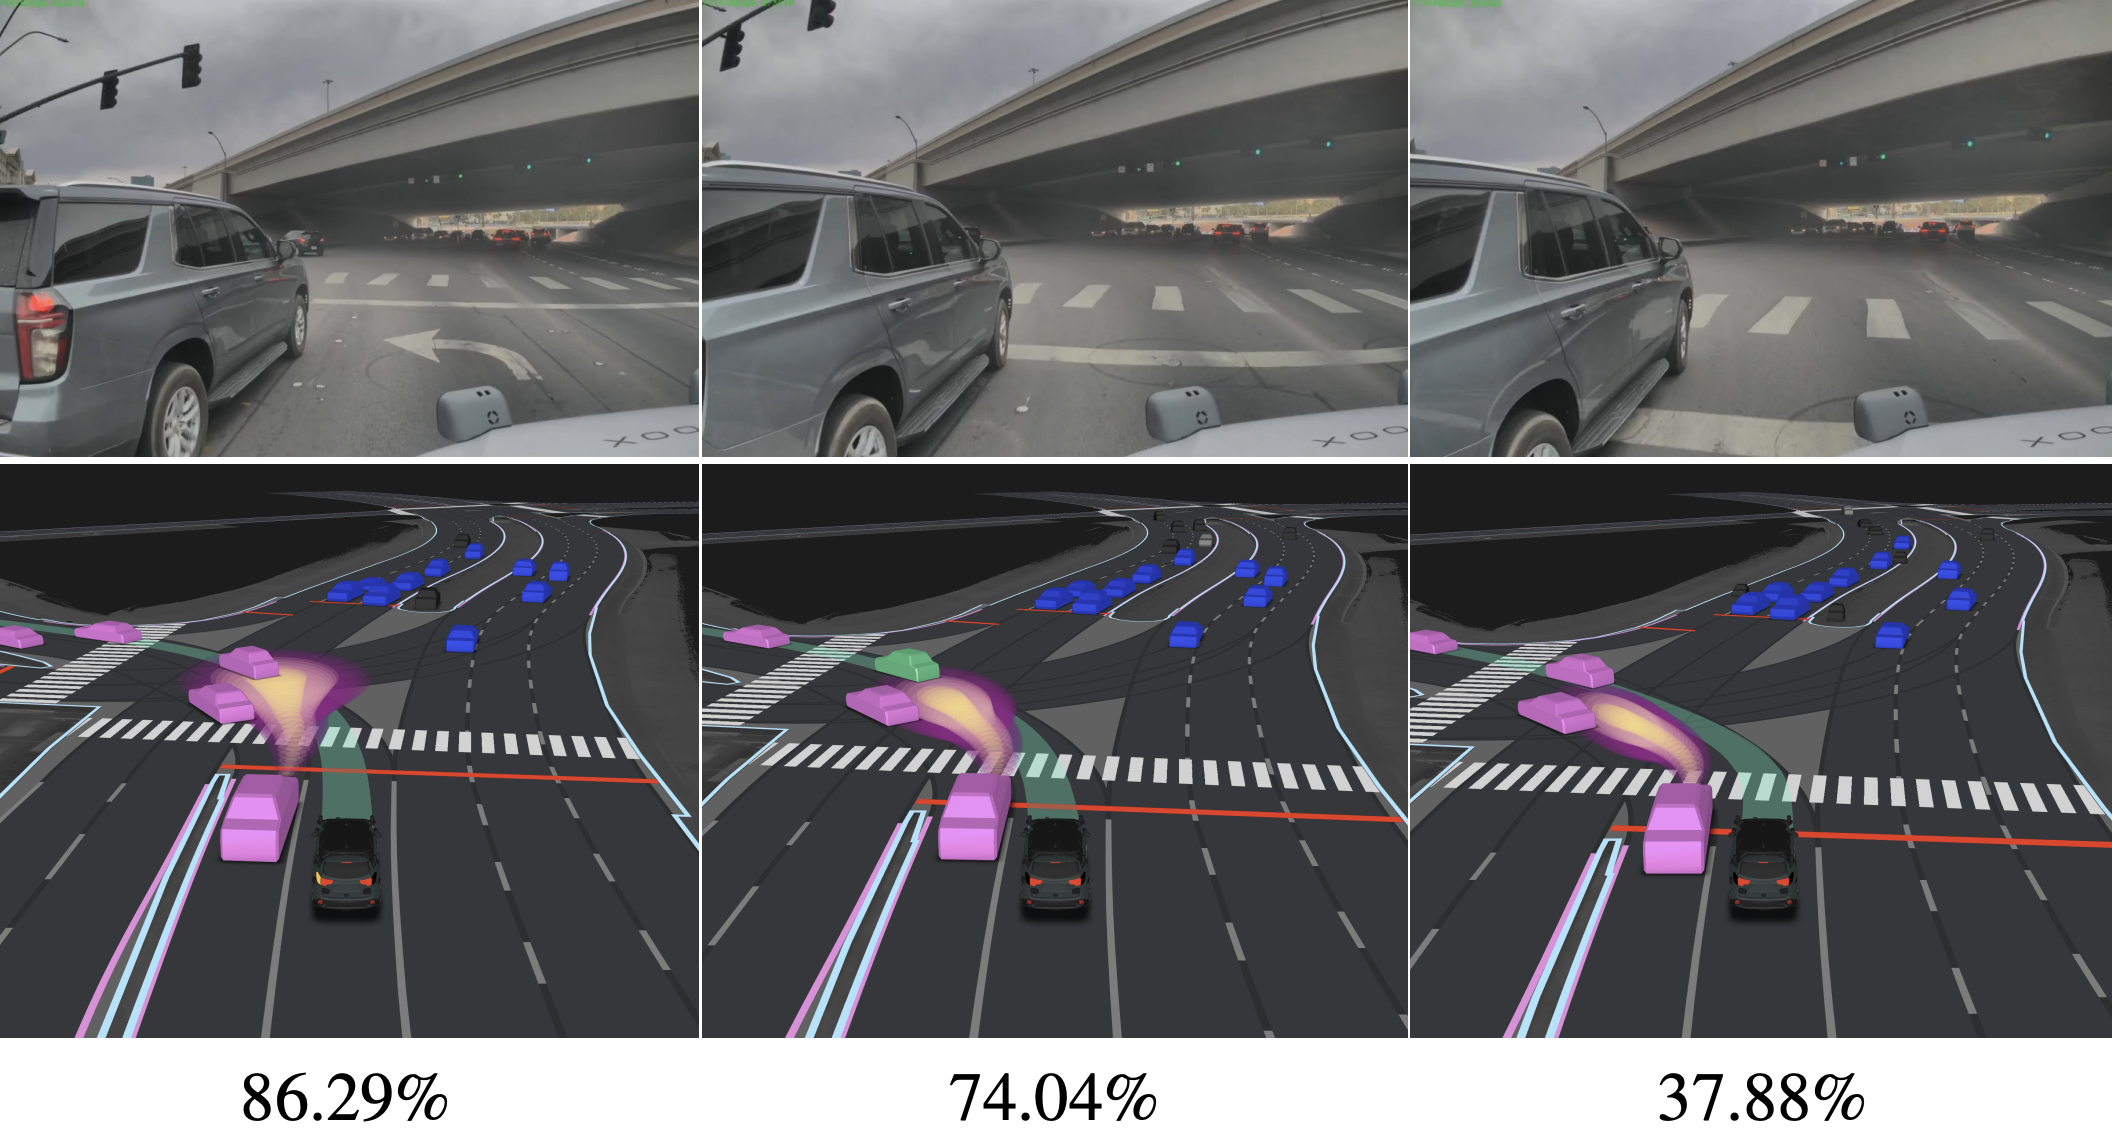
At Zoox, I developed algorithms that predict the motion of other agents/objects
around the vehicle, and to correspondingly compute collision probabilities. During my PhD, our
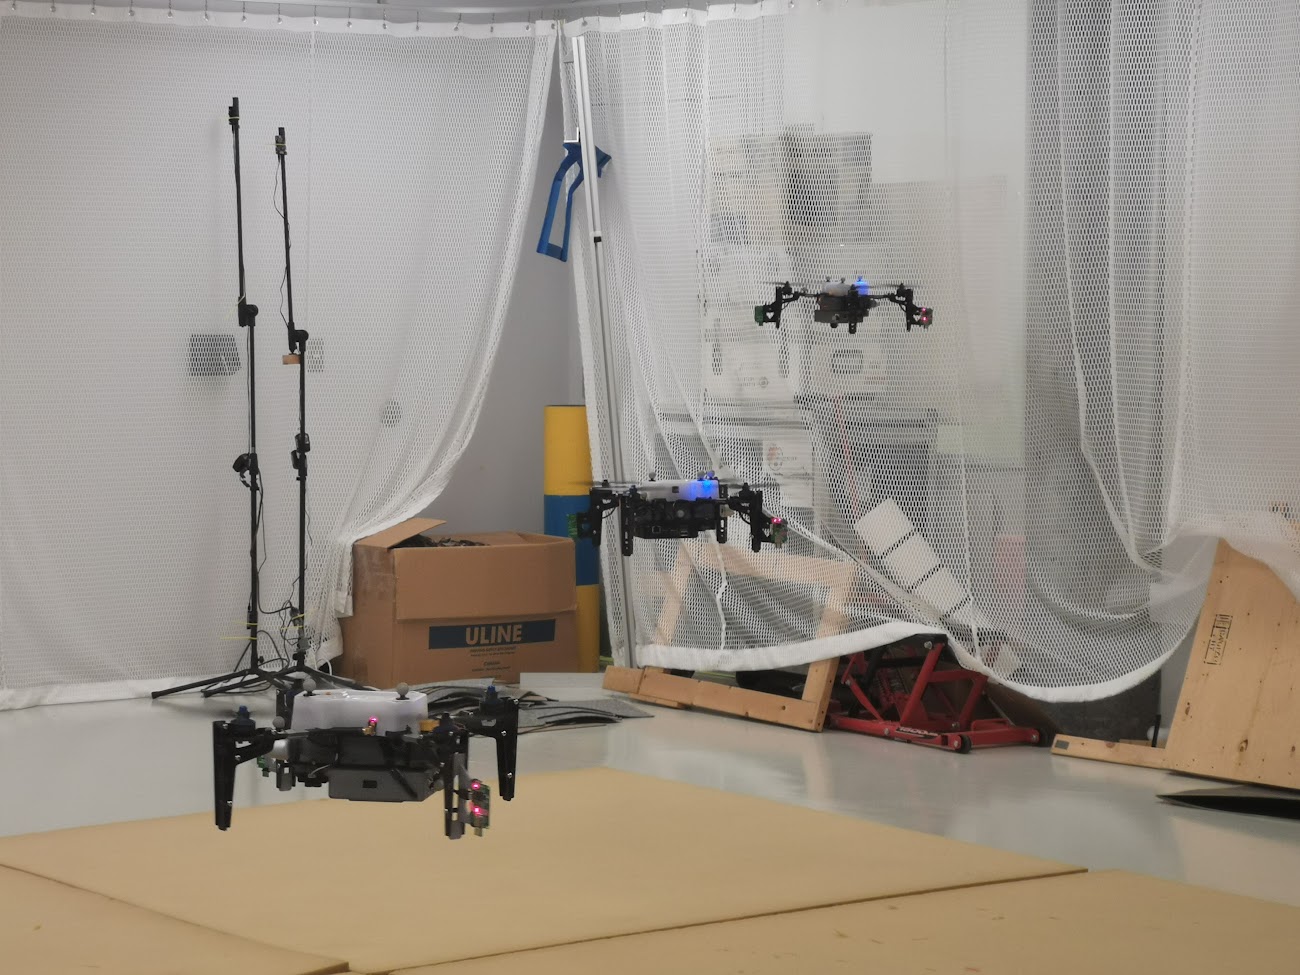
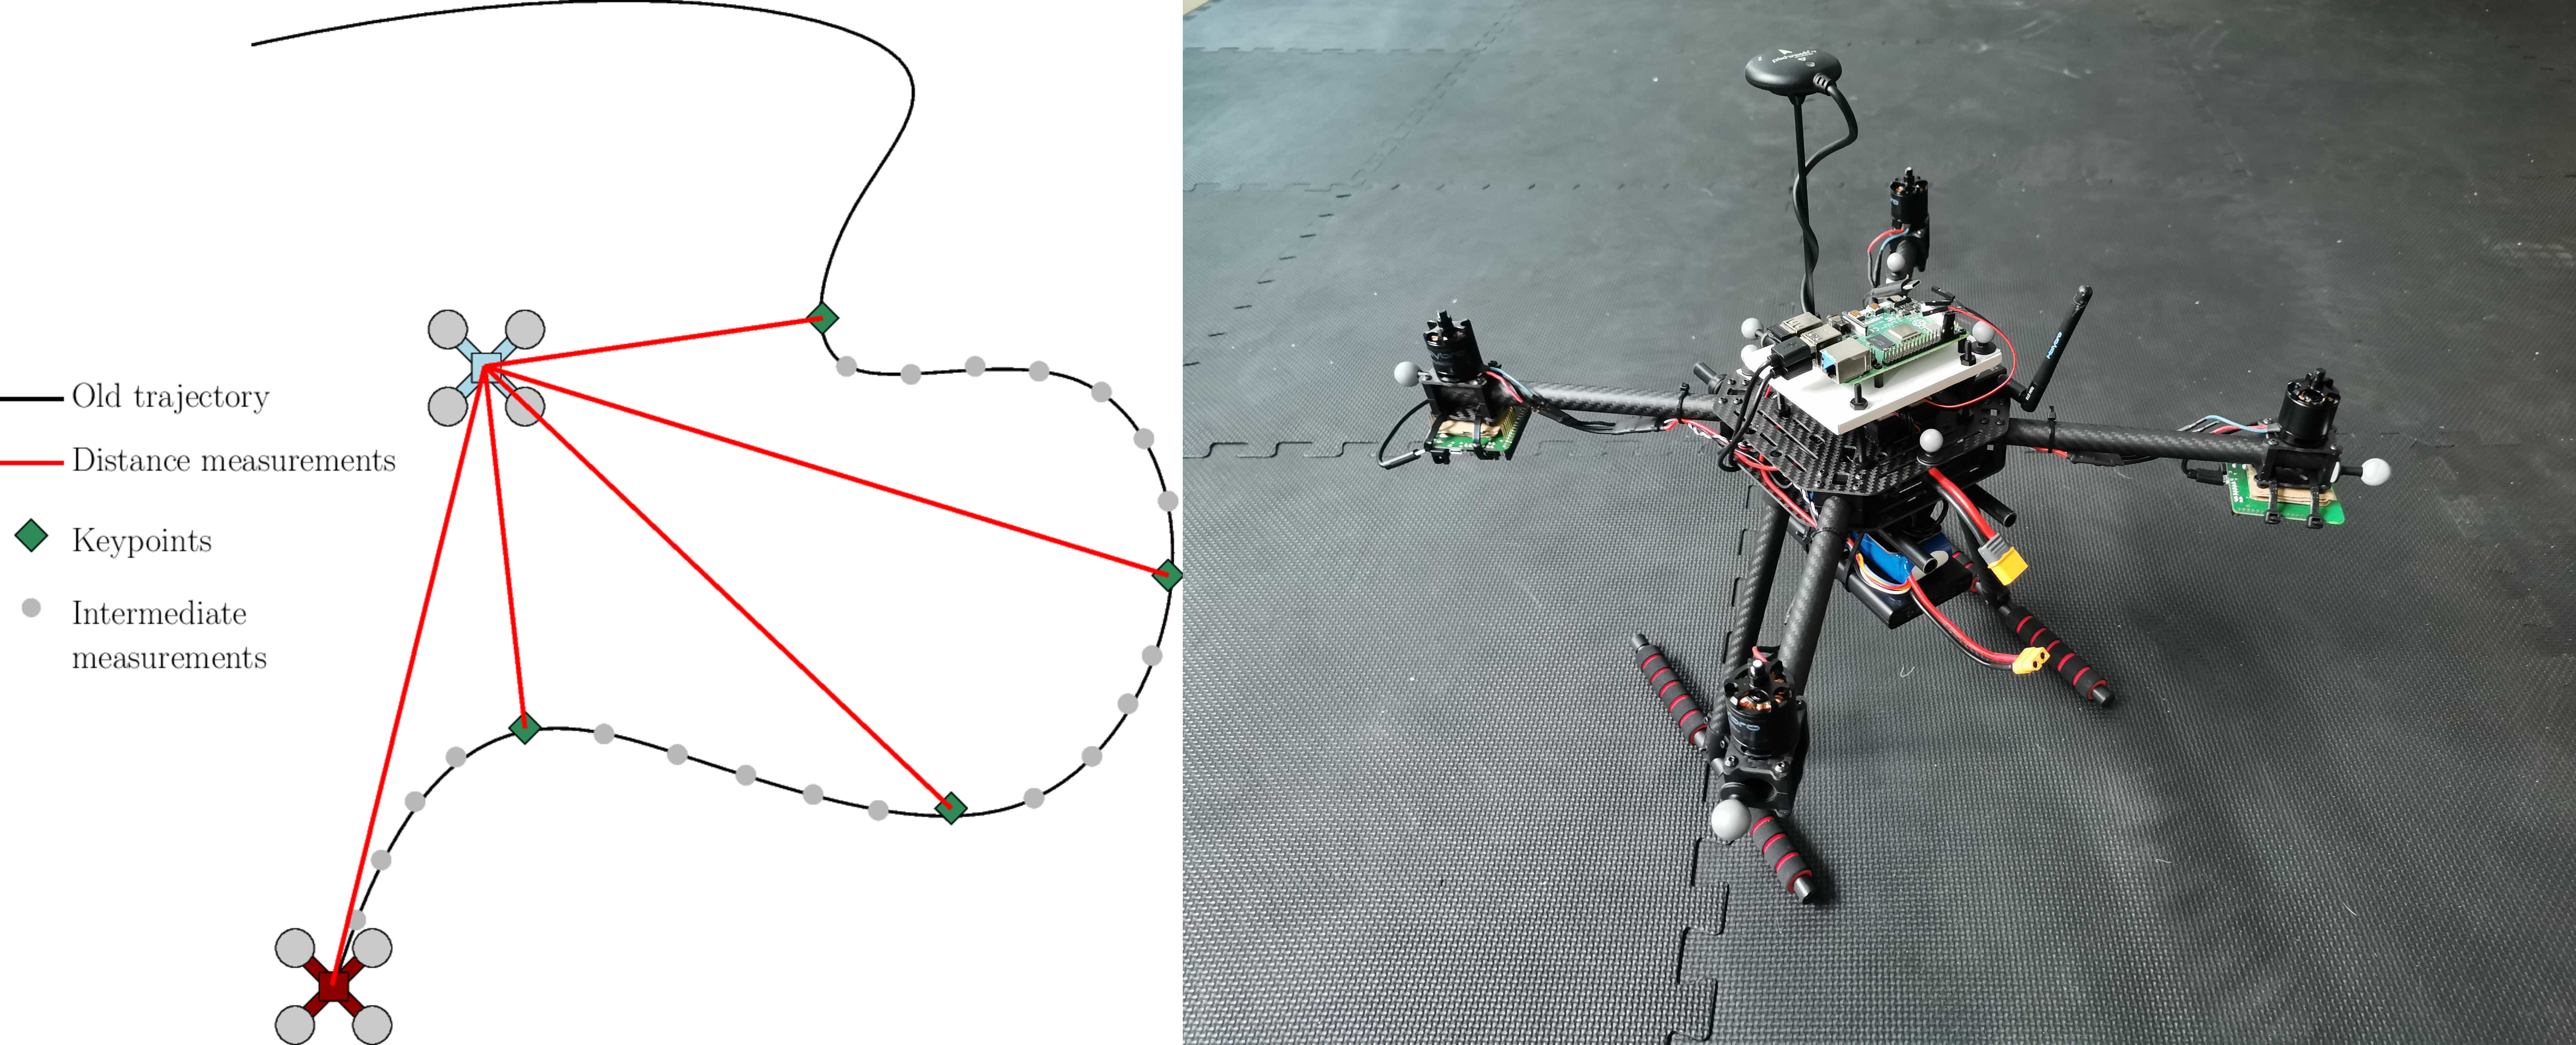
research focused on planning, estimation, and control algorithms for multi-robot teams. We
specifically researched how to best use ultra-wideband radio to enable collaboration between
robots.
Some things I've done